 CV
 Scholar
 Email
 LinkedIn
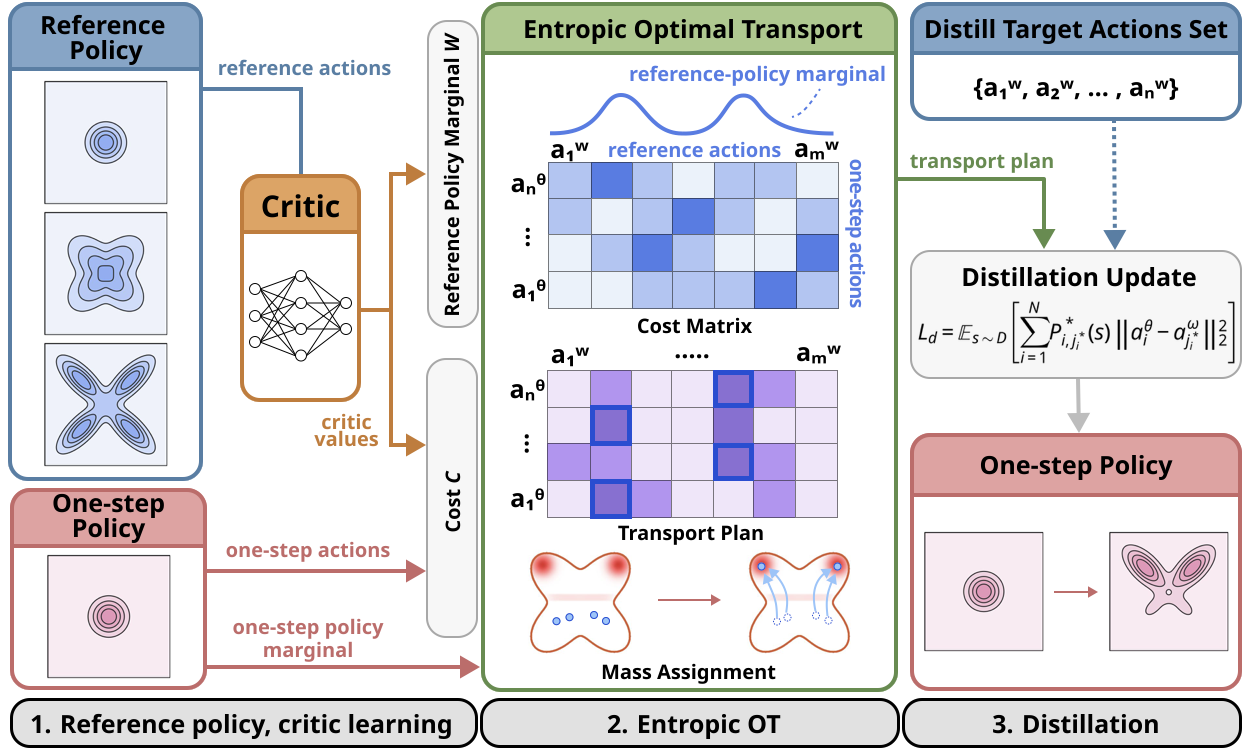
[C1] Learning Multimodal One-step Flow Policy via Value-weighted Optimal Transport
Physics-informed Dexterous Manipulation · Humanoid Learning · Reinforcement Learning
I'm Jinha Choi, an undergraduate student at Yonsei University, South Korea, majoring in Computer Science and Nano Science and Engineering and expected to graduate in February 2027.
I am currently advised by Prof. Yonghyeon Lee at RoPhi Lab at Yonsei University, working on high-DoF dexterous manipulation incorporating physics- and control-informed priors toward generalizable robot intelligence for unstructured environments and real-world deployment. Previously, I was a research intern at HuGeLab at KAIST, advised by Prof. Beomjoon Kim, where I worked on real-world deployment of humanoid locomotion policies. I also worked at DILLab at Yonsei University, advised by Prof. Jongmin Lee, on offline reinforcement learning that distills a value-aware multi-step flow policy into an efficient one-step policy using state-wise entropic optimal transport. Earlier, at Yonsei RLLAB, advised by Prof. Youngwoon Lee, I built humanoid locomotion baselines using retargeted motion priors and studied their effects on motion quality and stability.
[C1] Learning Multimodal One-step Flow Policy via Value-weighted Optimal Transport
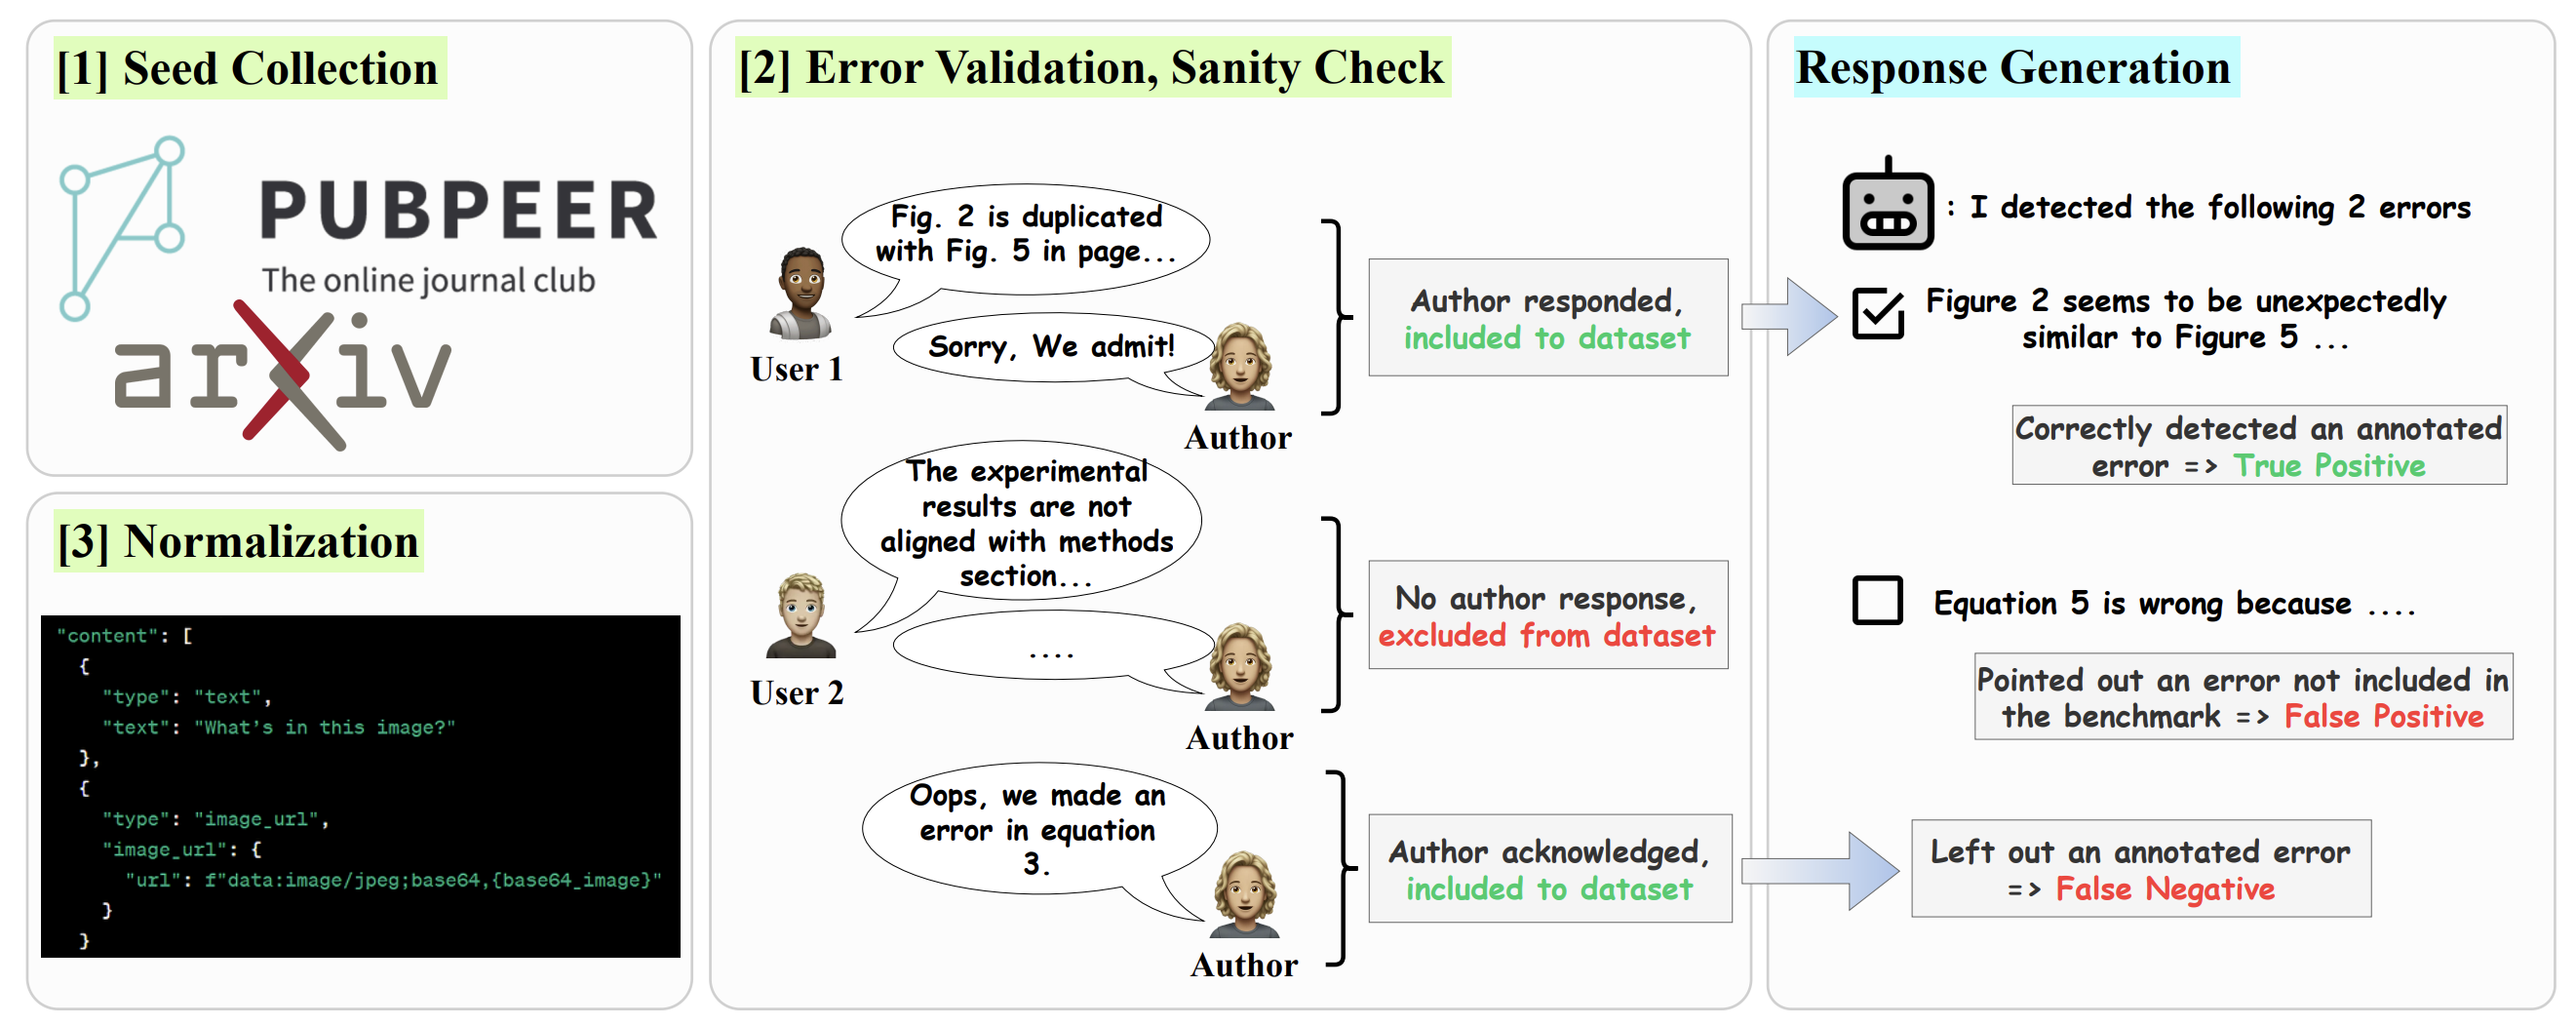
[P1] When AI Co-Scientists Fail: SPOT — a Benchmark for Automated Verification of Scientific Research
Grasping via Global Planning and Local Correction
Advised by Prof. Yonghyeon Lee
Franka FR3 Control and Perception
Advised by Prof. Yonghyeon Lee
Humanoid Deployment — Locomotion
Advised by Prof. Beomjoon Kim
Franka FR3 Teleoperation Data Collection
Advised by Prof. Beomjoon Kim
Humanoid Fixed-Base Manipulation
Advised by Prof. Youngwoon Lee
A1-Challenge Autonomous Driving Competition
Ministry of Trade & KIAPI
Physical AI Robotics Hackathon — Arm Manipulation
Kernel Academy & Doosan Robotics
Image Inpainting with LLMs and Diffusion Models
OUTTA AI Bootcamp
Korea Defense Intelligence Command — Translator
Military Service
VEX Robotics
Team Lead, 1010B, WVSS Robotics
Hyundai NGV Robotics Track H-Mobility Class Certificate
Mar – Jul 2026 · Hyundai NGV
Completed Hyundai’s Robotics Track in robotics and robot learning and received the H-Mobility Class Certificate.
2nd Place — Physical AI Robotics Hackathon
Mar 2026 · Kernel Academy & Doosan Robotics
Presented a manipulation pipeline and demonstrated perception-guided grasping at the Kernel Academy hackathon.
Top Award — Korea Defense Intelligence Command AI Security Competition
Awarded by Major General Sangho Moon (OF-7), Commander, KDIC
Proposed an on-device AI framework for military systems with partial internet exposure, designed to support operational convenience while strengthening protection against security vulnerabilities and malicious misuse.
Honor Roll — Yonsei University
Jul 2022
Recognized for academic performance in the top 3%.
1st Place — Yonsei–Nexon RC Creative Platform
Mar – Dec 2021
Led a five-member team to develop an automated revolving-door assistance system for people with mobility impairments; ranked 1st of 90 teams and received a $10,000 award.
Division Finalist — VEX Robotics World Championship
Nov 2019 · Kentucky, USA
Reached the Science Division final in a 100-team division within a field of 600 qualified teams.
1st Place — VEX Robotics Canada BC Provincial Championship
Jun 2019
Won the British Columbia Provincial Championship and qualified for the VEX Robotics World Championship.
Feel free to reach out for research discussions, collaboration, or general inquiries.